Project
Quad Simulation
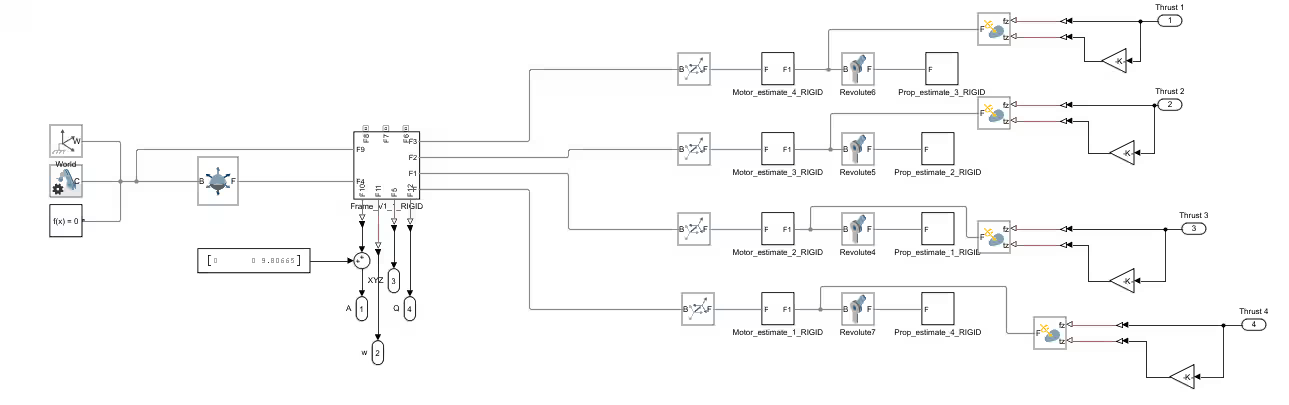
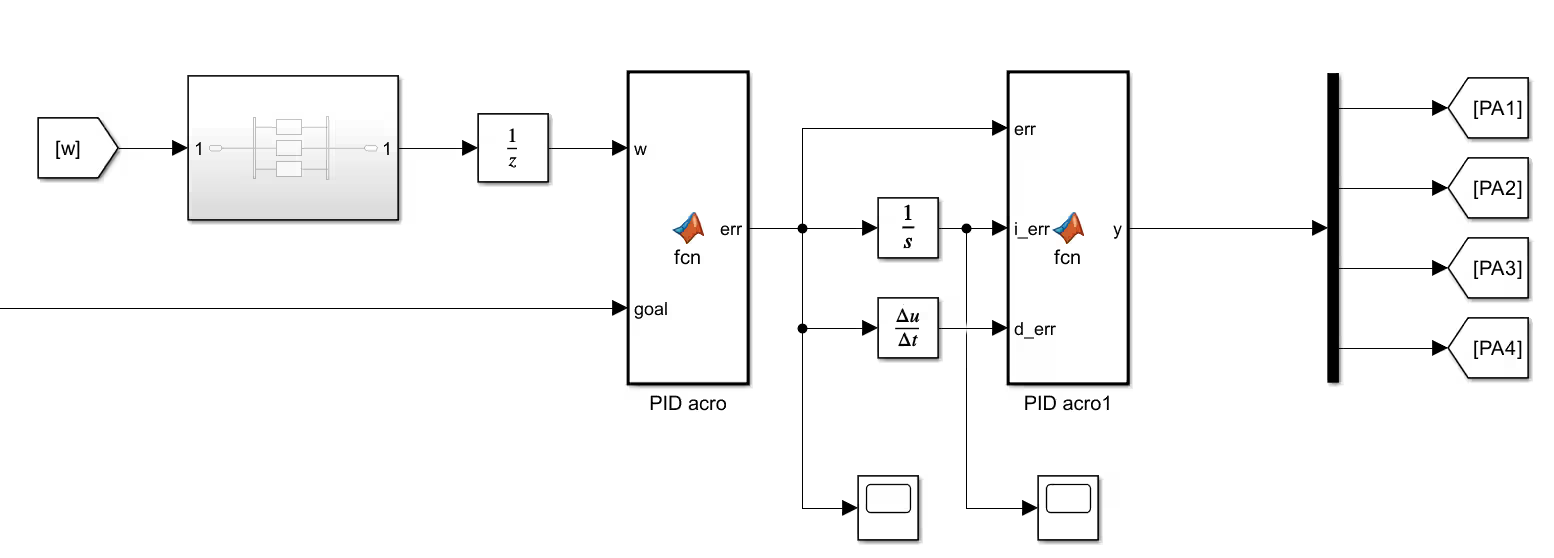
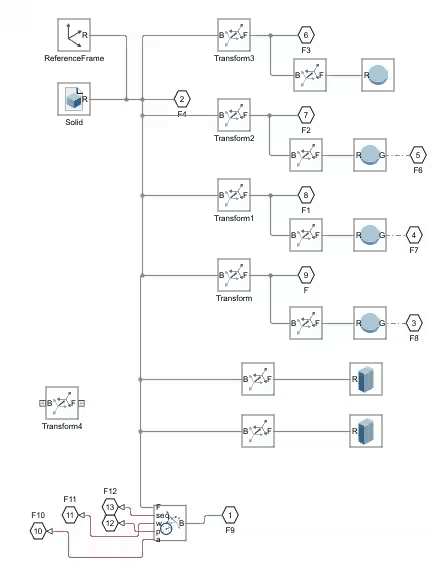
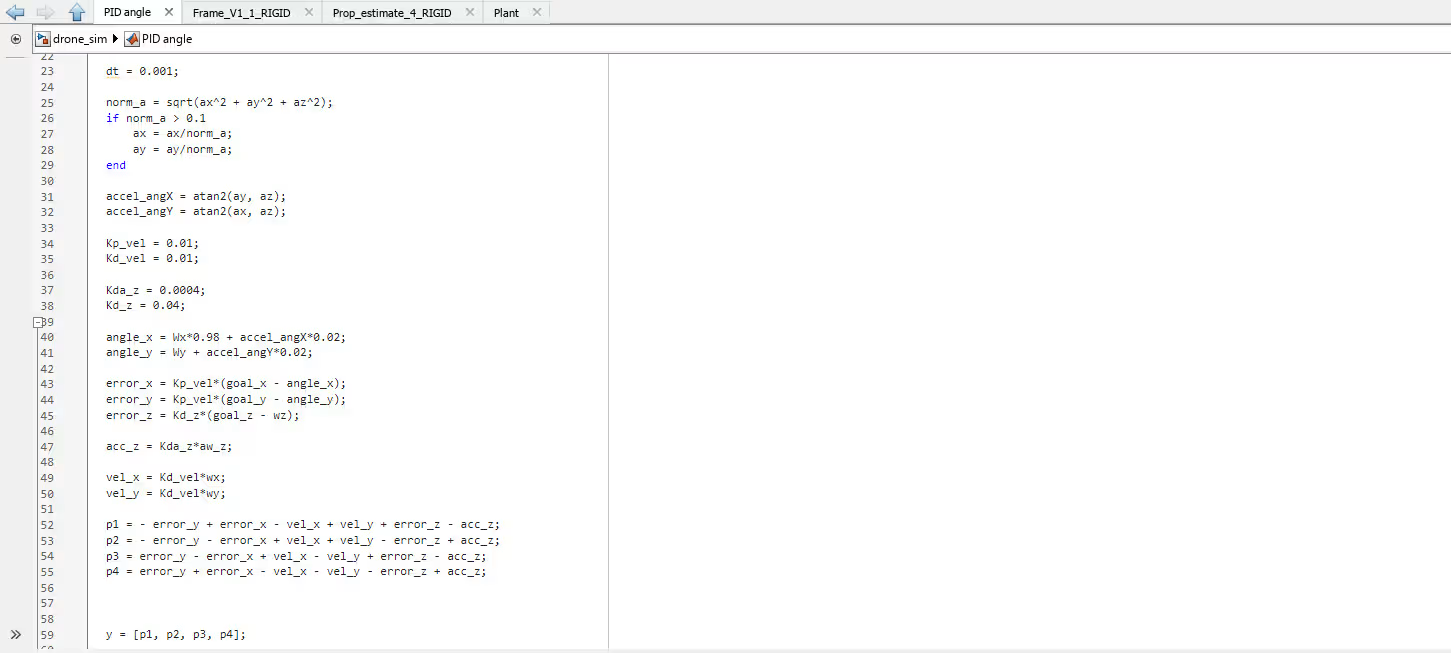
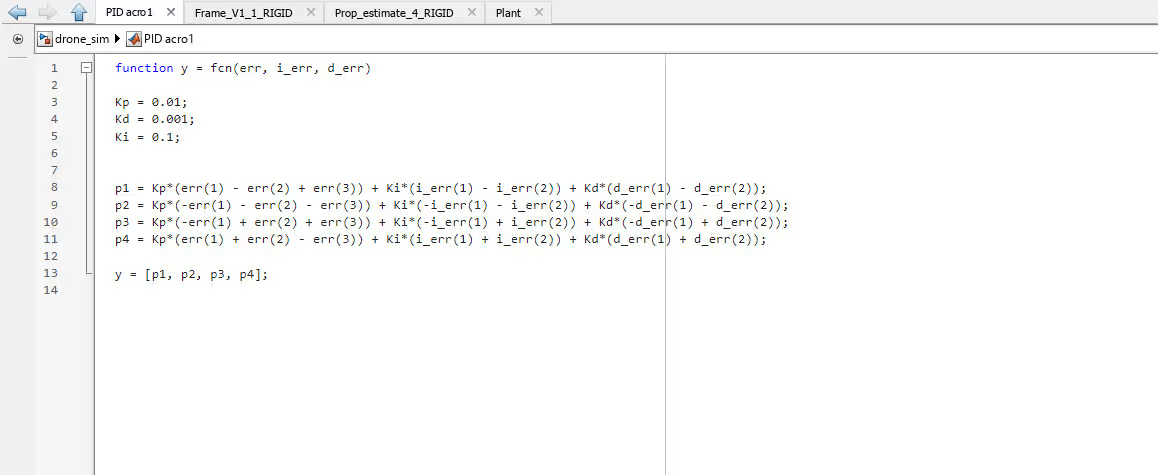
The purpose of this project was to learn about the Simscape tool in Simulink, and to better understand the dynamics of a quadrotor system. The project involved designing a CAD model of a whoop drone in SolidWorks, before importing the model into Simscape and modeling the dynamics of the system. The project also involved designing a control system for the quadrotor, and evaluating the performance of the system through simulation.
Final product
Drone Acro Flip
Drone performing two flips using acro control mode and stabilizing itself afterward.
Simulation
System Model